It has only been two months since GPT-6 Astra was released, and GPT-6.2 Astra is already looming on the horizon.
Yet the embodied intelligence industry has not yet recovered from the previous blow.
Everything happened so suddenly and caught people off guard.
I still remember that when GPT-6 Astra first came out, a group of embodied AI practitioners were stunned. Engineers working on pretraining on the front lines, in particular, were all fearing for their jobs.
Recently, news has circulated in the industry that some embodied intelligence companies have begun to cut algorithm positions.
Capabilities that used to require a large amount of data, compute, and algorithm engineers to
Diandian
grind out, GPT-6 Astra can demonstrate in some tests without additional post-training for specific tasks.
How are people supposed to compete anymore???
An engineer working on model development at a robotics company told Quantum位:
Compared with the fact that embodied intelligence has yet to see a new paradigm-level breakthrough, general large models represented by Astra are striking the embodied industry vertically through coding. That is the real shock.
The pressure brought by the shock does not come entirely from Silicon Valley.
Compared with the technological progress of overseas large model companies such as OpenAI, domestic embodied companies are more sensitive to the next moves of local large model players.
Kimi
,
DeepSeek
, Zhipu... These names are becoming variables that the embodied industry has to pay attention to.
In the recently popular RoboDojo evaluation, more and more teams have also begun trying to introduce general large models (such as GPT-6 Astra) into their own robot systems, with strong generalization and astonishing capabilities.
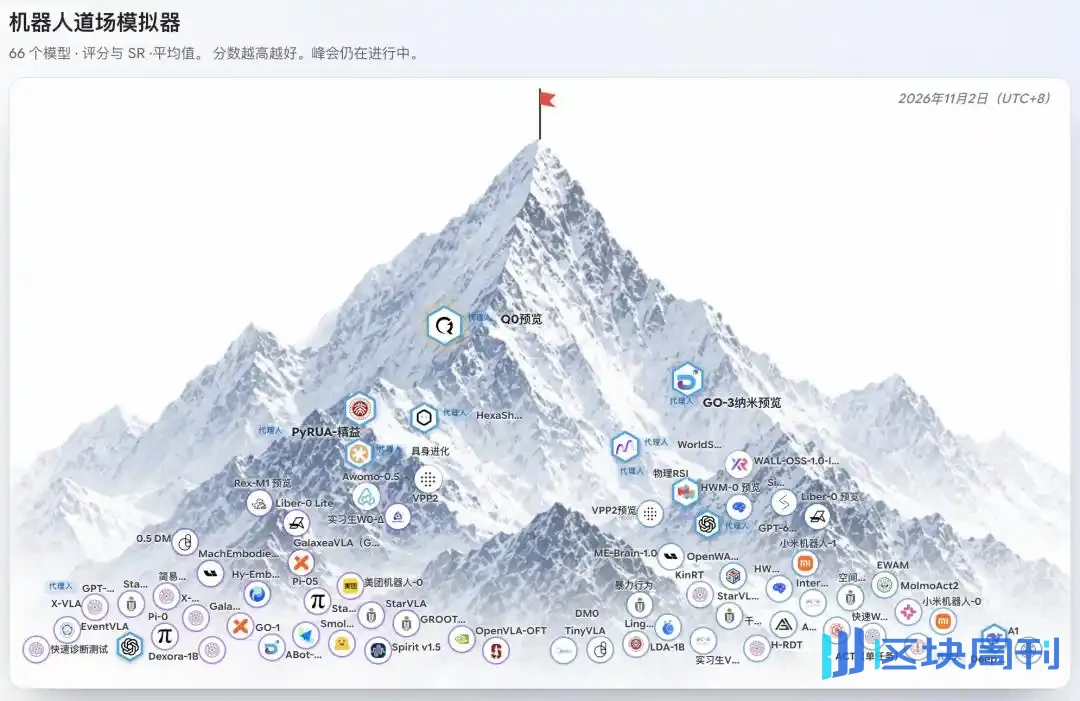
According to Chen Tianxing, first author of the RoboTwin/RoboDojo evaluation benchmark, some teams that originally insisted on training native embodied foundation models are now also beginning to submit solutions combining technologies such as Robot-Use-Agent (RUA), using general large models to complete robot tasks.
The effect is quite direct. Models that originally scored only 20 or 30 points can, after combining Astra-related solutions, improve their evaluation scores to 50 or 60 points.
The leaderboard scores have gone up, but embodied companies have only one thought in their heads:
Is it still necessary to develop models in-house... (cry)

As a PhD student in the embodied intelligence direction at the University of Hong Kong MMLab, Chen Tianxing participated in the writing of RoboDojo's evaluation and assessment report on GPT-6 Astra (hereinafter referred to as the "report").

△The RoboDojo team's early evaluation report on GPT-6 Astra
Recalling a day in mid-September, Chen Tianxing told Quantum位 that when his partners brought the test results one after another, he was stunned for several seconds:
You can see that its impact on 3D reconstruction, mathematics, and various other fields is unprecedented.
Frightening, really quite frightening.
Everyone was stunned by GPT-6
"Embodied in-house models are still adding 0.1 and 0.2 points on top of 80 points, while GPT-6 Astra has already jumped from 80 points to 90 points in one go."
This is a vivid analogy Chen Tianxing gave when reviewing this evaluation.
What is even more striking is that in some tests, Astra did not even undergo additional post-training for specific tasks, nor did it use task demonstrations; relying solely on language instructions, it was able to complete quite a few robotic manipulation tasks.
What surprised him most was that Astra suddenly demonstrated three capabilities that embodied models previously had to focus on overcoming.
The first is ICL (In-Context Learning).
Simply put, it allows a robot to quickly learn a new task through a small amount of contextual information.
For example, if a human records a video of themselves performing an operation and adds text descriptions, the robot can understand how the human did it and attempt to have the robotic arm reproduce it.
In July of this year, ICL was still a fairly popular research direction in the embodied AI community. The common paradigm is to demonstrate human operations and have the robot imitate them to acquire new skills—so-called one-shot in-context learning.
But the community found that providing Astra with image or text demonstrations could yield a higher success rate than not providing demonstrations.
Even more surprising was its online adaptation capability. Researchers deliberately changed the camera view and action coordinate system, and Astra was able to adjust its strategy after several rounds of attempts based on actual execution results, successfully completing the task.
In other words, it can not only understand context, but also correct itself while acting.
In Chen Tianxing's view, this is because general models themselves have strong contextual understanding capabilities. During ordinary chat, it can remember previous conversation history; given a video, it can also understand the relationship between the video content and the text.
Transferring these capabilities to robotic manipulation means that the ICL problem, which originally required dedicated research, suddenly has an off-the-shelf solution.
The second is OOD (Out-of-Distribution) generalization and Correction capability.
In real environments, robots easily encounter situations outside their training data.
For example, a robotic arm is about to grasp a cup, but the cup is suddenly bumped and its position changes.
A model that relies excessively on training data might still execute along the original trajectory and end up grasping at nothing.
Astra, however, can readjust its actions based on the changed visual information and attempt to grasp the object.
It sounds like just a tiny action, but behind it lies the question of whether a robot can adapt to the real world.
After all, in the real world, no one is responsible for placing every cup back in its training-time position.
The third is Open-Vocabulary Manipulation.
This capability involves the alignment between language and actions.
For example, if a user phrases an operation request in different ways, the robot can still understand and execute it.
In the past, there was often a disconnect between language understanding and action execution, and embodied models needed post-training for specific tasks to better achieve alignment.
But Astra has demonstrated stronger capabilities in this regard. In some tests, even without additional post-training and demonstrations for specific tasks, it could complete quite a few robotic manipulation tasks relying solely on language instructions.
In Chen Tianxing's view, the above three were once highly significant technical propositions in the embodied AI field, and in the past each could have been presented as a standalone startup story.
Now, Astra has solved all three at once, which is an almost explosive shock to the original embodied model R&D路线.

△Zero-shot test results on the RoboDojo-Sim benchmark do not mean that Astra can already stably complete these tasks on real robots.
In the report, the RoboDojo team noted that Astra's real-machine testing was once suspended due to safety issues.
High scores on a simulation leaderboard cannot yet be directly equated with productivity in the real world.
But it is already enough to make embodied companies re-examine their past R&D investments.
Why can a general large model that was not originally built for robotic manipulation rapidly approach capabilities that embodied companies have accumulated over years?
It is somewhat an unintended success.
Although general large models did not start learning robotics from scratch, they entered the robotics field carrying a series of capabilities accumulated during large-scale pretraining, such as language, vision, reasoning, and coding.
These capabilities originally each had their own uses, but unexpectedly, when applied to robots, they can also be put to direct use.
In contrast, many embodied companies train robot brains from scratch, and the data they have mainly comes from robotic manipulation itself.

For the model to understand the environment, understand instructions, and learn actions, many capabilities must be
Diandian
ground out from limited data.
One enters robotics with a full set of general capabilities, while the other is still investing data, compute, and manpower separately for each capability.
In this contest, the starting lines themselves are different.
Is there still a need for self-developed models?
GPT-6 Astra is indeed very strong, but it is not yet strong enough to make embodied companies simply lay down their arms and surrender.
At least in the real physical world, there are still many hard nuts waiting to be cracked.
Xu Huazhe, founder of Pokebot, breaks down embodied intelligence capabilities into three levels: semantic, spatial, and physical generalization.
He believes that Astra performs outstandingly on the first two, but still faces challenges in complex physical contact, force changes, object deformation, and high-precision manipulation.
For example, letting a robot know where a cup is and that it should reach out to grasp it is completely different from letting it steadily grasp a cup.
Is the cup soft or hard? How much force should be used when grasping? What changes occur after the object is squeezed or collided with?
These problems cannot be solved by merely understanding the visuals and comprehending instructions.

△Report screenshot
The RoboDojo team also found in their evaluation that Astra does not outperform on all tasks.
Geometric alignment and language instruction understanding are its strengths, but when it comes to continuous contact and multi-step physical manipulation, existing VLAs still have plenty of room to improve.
Wang Qian, founder of X Square Robot, holds the view that for general large models to enter embodied AI, they must still confront infrastructure issues such as robot data, real-world evaluation, hardware, simulation, and deployment.
These difficulties will not automatically disappear just because one has a more powerful language model.
The question is, will the things Astra cannot do well today suddenly become achievable tomorrow?
Currently, another common criticism of Astra in the industry is that its inference speed is too slow.

Chen Tianxing also noticed that the GPT-6 Astra cloud API has relatively high inference latency, which is a real obstacle for real-time closed-loop robot control.
Think about it: if a robot has to wait for the large model to think for a long time before every action, it would probably be hard to meet the requirements of real-world scenarios.
But Chen Tianxing believes that this problem is not a fundamental barrier; there are already many existing on-device LLM deployment solutions, including technologies such as model quantization, distillation, and on-device inference engines. As long as large model companies regard robotics as an important commercial scenario, they can use the existing technology stack to complete latency optimization.
Behind this problem lies a concept that is very easy to confuse: "model inference frequency" and "robot control frequency" are not the same thing.
An embodied model engineer who declined to be named told QbitAI:
Slow inference can still allow fast control; what is sacrificed is only reaction speed. For assembly-line tasks that are more rhythm-dependent, this is actually irrelevant.
For example, in express parcel sorting, robots need to grasp and place continuously and stably. The high-level model is responsible for understanding the task and planning actions, while the low-level control system executes control commands at a higher frequency.
As long as the task allows advance planning, or has a certain tolerance for reaction latency, the large model does not necessarily need to participate in every low-level control cycle.
Of course, for tasks involving high-speed dynamic changes and complex contact, reaction speed is still important.
But at least, slow inference does not necessarily mean the robot's control is not fast.

The various shortcomings exposed by today's general large models cannot be directly treated as the moat that embodied companies will rely on for survival in the future.
For embodied companies, this truth is somewhat painful to hear.
But the facts are there. This year, OpenAI has already begun recruiting a large number of robotics-related positions.
If general models absorb more robot manipulation data in the future, the capability boundaries originally belonging to specialized embodied models may continue to be compressed.
Do embodied companies still have opportunities? Is self-developed modeling still necessary?
Chen Tianxing's judgment is that the opportunity for embodied companies does not lie in whose model is smarter, but in who can create better "economic benefits."
This account is easy to calculate.
On a highly standardized industrial assembly line, where robots repeat the same actions every day, customers care most about success rate, cycle time, stability, and cost.
If spending a few cents to call a model can stably complete the task, why insist on spending a few dollars to call GPT-6 Astra?
Even if a certain level of intelligence and generalization capability is required, a small model that has been specially optimized may be more economical than directly calling Astra.

Of course, if it is a home service robot, the situation is different.
Today it tidies the table, tomorrow it looks for items, and the day after tomorrow a new task it has never seen before arrives.
In such an open environment, the more tasks vary, the higher the requirements for understanding, planning, and generalization capabilities. A stronger general model may instead have more advantages.
On November 6, Chen Tianxing explained the difference on his personal blog using two axes.
The left side is "scenario requirements," and the right side is "model capabilities." The higher up, the more emphasis on generality; the lower down, the more emphasis on efficiency.

△Chen Tianxing's blog
"Open tasks can rely more on general models, stable tasks can adopt rules or lightweight strategies, and the scenarios in between leave room for scenario-optimized models," said Chen Tianxing.
In my view, putting the two axes together comes down to one sentence:
If something can be solved with rules/lightweight strategies, there's no need to bring in a large model; if a task can be completed with a small model, there's no need to call in Astra every time.
Conversely, if tasks vary too much, specialized models need to continuously collect data and retrain, so directly calling a general model may be more cost-effective.
Deciding which approach to adopt ultimately requires calculating a complete economic account.
What is the success rate of a single task? How much time does it take? How much manual intervention is needed after a failure? How much does data collection, model training, and long-term deployment cost?
These concrete numbers determine whether a robotic system has commercial value.
So, it's not that in-house development is unimportant, but that the "in-house development directions" of embodied companies need to be reordered.
Capabilities that general models are already good at, such as language understanding and task planning, can be considered for direct use; issues involving physical interaction, specific body control, real-scenario adaptation, and deployment efficiency still require substantial specialized research and development.
As for whether it's necessary to continue training a larger embodied foundation model from scratch, it depends on whether it can provide sufficiently obvious and sufficiently lasting advantages in actual tasks.
Some industry friends complained to Quantum位 that many embodied teams still carry a fairly strong academic mindset, always thinking about building a general intelligence model and wishing they could stuff all tasks into their own model.
But the situation has changed now. GPT-6.2 Astra is about to arrive.
If a company's research direction is disconnected from its target industry, no matter how beautifully the model is trained, the commercial loop may not necessarily hold.
One more thing
Over the past 60 days, many embodied industry practitioners, when chatting privately, are still confused.
It's just that in public settings, when it comes to defending their own interests and positions, they still have to hold their ground to the end.
What is certain is that GPT-6 Astra has indeed disrupted the original rhythm of the embodied industry...
The Matthew effect, the industry revaluation after Unitree's IPO, RSI becoming a new hot spot... all stacked together, ultimately forming the recent industry sentiment—
"Investors are starting to stop investing in embodied AI."
There may be some exaggeration, but it is utterly true that embodied intelligent robot startups are bidding farewell to the Demo and investment-burning stage.
The elimination round of the hundred-machine battle has already begun.
This article comes from the WeChat public account "Quantum位" (ID: QbitAI), author: Focus on Frontier Technology